How it works
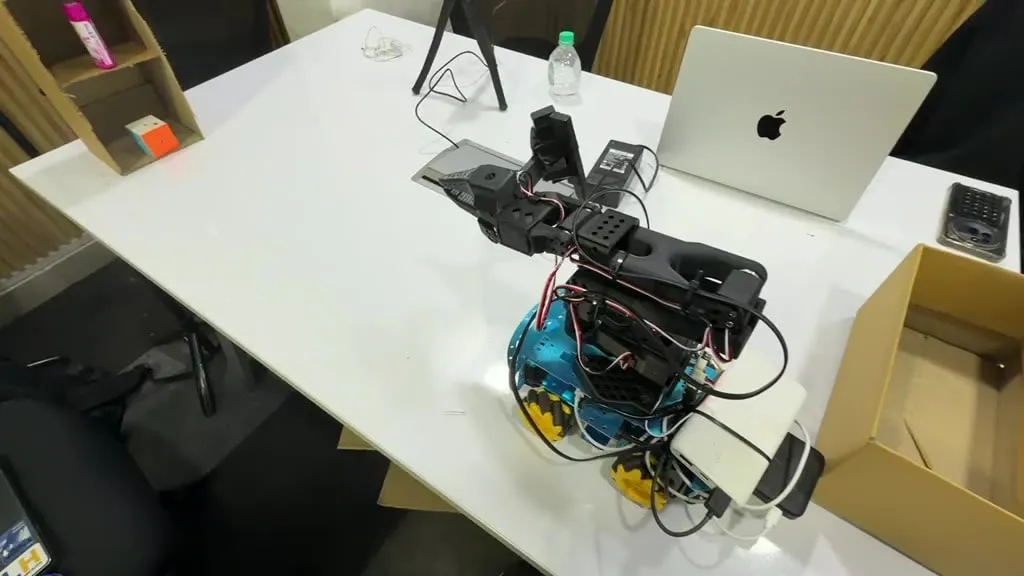
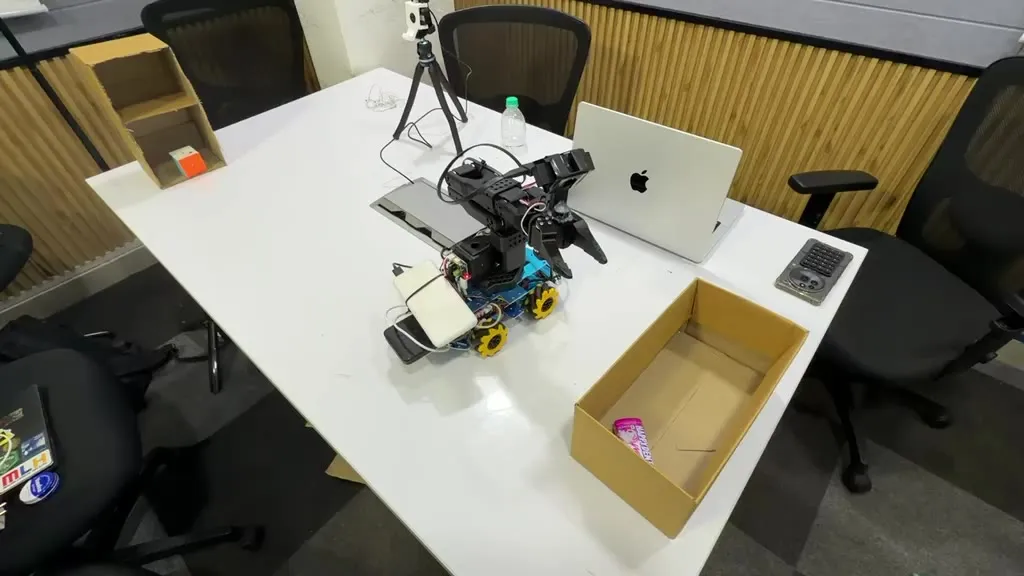
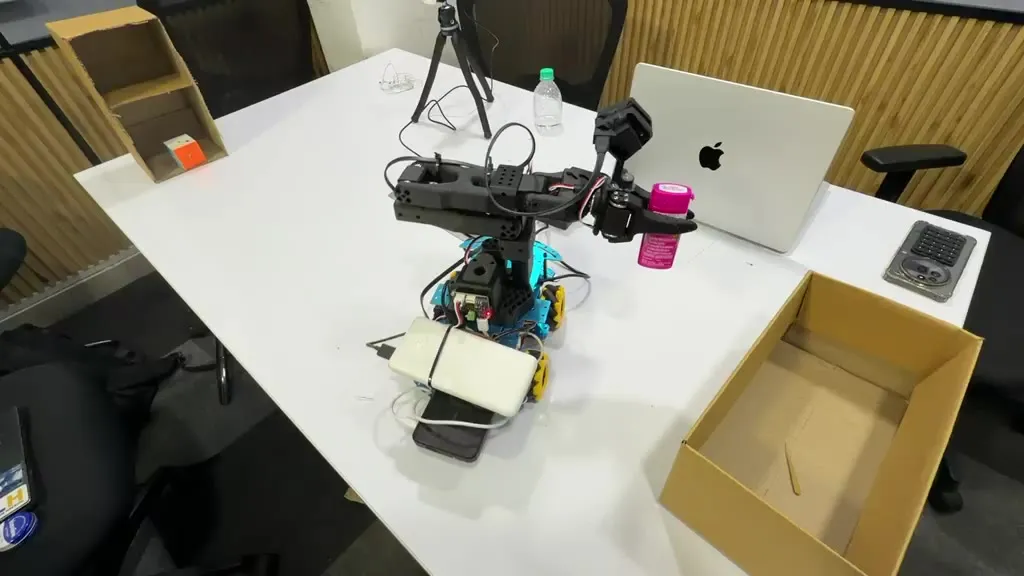
Every 10 minute delivery starts with a person walking the aisles. We wanted a robot to do that walk: a robot arm on a small base with wheels that move in any direction.
The arm learned to pick by copying us. We recorded our own pick runs with a controller and fine-tuned an ACT model on them. A Raspberry Pi runs the robot and one camera sits on the gripper.
Around it we built a dashboard for orders, live camera and checks, plus Overwatch, an outside camera that spots dropped items.
What stuck
How many times a policy has to be trained before it works. I would not have understood that without doing it.
Stack
SO-101 arm / LeRobot / ACT / Raspberry Pi / MuJoCo / FastAPI / React / three.js / Python